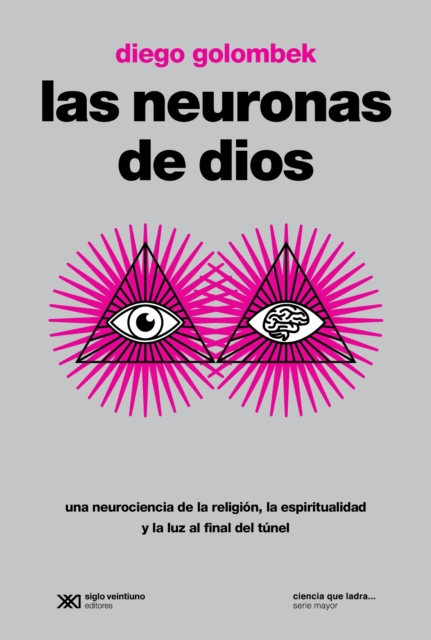
¿Por qué, en pleno siglo XXI, seguimos creyendo en algo o alguien superior, llámese Dios, meditación trascendental, espiritualidad o sentido de la vida?
Las fotografías suponen una particular forma de conocer la realidad social, pero también de crearla, entiende la historiadora Inés Yujnovsky en la introducción de este libro que, en vez de considerar la fotografía como reflejo de la realidad apunta a confrontar esas ideas y abordar este lenguaje como un agente de transformación.
AIICSR '97 (Artificial Intelligence and Information-Control Systems of Robots) is one of the most traditional East-West professional meetings devoted to artifical intelligence (AI) and its applications in robots.
This volume provides doctorate students and professionals with basic and advanced material on modelling and control of complex mechanical systems, with particular emphasis on robotic manipulators.
This book presents an extensive survey of the state-of-the-art research in parallel computational algorithms and architectures for robot manipulator control and simulation.
This text features a broad array of research efforts in computer vision including low level processing, perceptual organization, object recognition and active vision.
In recent years works done by most researchers towards building autonomous intelligent controllers frequently mention the need for a methodology of design and a measure of how successful the final result is.
This book describes non-conventional methods of control of human extremities, emphasizing the fact that conventional approaches used in robotics are limited when used in humans for restoration of reaching and grasping (goal-oriented movements), and standing and locomotion (cyclic movements).
Obstacle Avoidance in Multi-robot Systems: Experiments in Parallel Genetic Algorithms offers a novel framework for solving the path planning problem for robot manipulators.
Recently, there has been considerable research interest in neural network control of robots, and satisfactory results have been obtained in solving some of the special issues associated with the problems of robot control in an "e;on-and-off"e; fashion.
This book surveys the history of automatic vehicle guidance based on the processing of visual information, starting from the very first projects worldwide up to the latest developments.
This volume presents the editors' research as well as related recent findings on the applications of modern technologies in electrical and electronic engineering to the automation of some of the common manufacturing processes that have traditionally been handled within the mechanical and material engineering disciplines.
Theorizing the Southeast Asian City as Text examines the ways in which culture, ethnicity, languages, traditions, governance, policies and histories interplay in the creation of the urban experiences in contemporary Southeast Asian cities.
Flexible robotic manipulators pose various challenges in research as compared to rigid robotic manipulators, ranging from system design, structural optimization, and construction to modeling, sensing, and control.
The main goal of this book is to prove analytically and validate experimentally that synchronization in multi-composed mechanical systems can be achieved in the case of partial knowledge of the state vector of the systems, i.
This invaluable book comprehensively describes evolutionary robotics and computational intelligence, and how different computational intelligence techniques are applied to robotic system design.
An important obstacle in Minimally Invasive Surgery (MIS) is the significant degradation of haptic feedback (sensation of touch) to the surgeon about surgical instrument's interaction with tissue.
This book covers the most attractive problem in robot control, dealing with the direct interaction between a robot and a dynamic environment, including the human-robot physical interaction.